Youngeon Kim
Mobile Robotics Engineer · Korea Electronics Technology Institute (KETI) · Seoul, Korea
I am Youngeon Kim, a mobile robotics researcher and engineer at the Korea Electronics Technology Institute (KETI).
Research interests, Multi-robot system and Sim-to-Real, LiDAR-inertial-visual localization and mapping, Traversability for outdoor and multi-floor environments, and vision-language models(VLM) as the decision layer for autonomy.
I believe robotics has the potential to make our lives better by solving real-world problems in new ways. I'm passionate about exploring new ideas and turning them into practical robotic solutions. My goal is to keep growing as an engineer and contribute to making robots more useful in the real world.

Youngeon Kim (김영언)
Intelligent Robotics Research Center, KETI
"Better today than yesterday."
Experience
| Period | Organization | Role |
|---|---|---|
| 2023.05 – present | Korea Electronics Technology Institute (KETI), Intelligent Robotics Research Center, Seoul | Researcher, Mobile Robotics — multi-robot fleet management, autonomous navigation, SDR/OTA, simulation, anomaly detection |
| 2022.08 – 2023.03 | Korea Institute of Robotics and Technology Convergence (KIRO), Robot Vocational Innovation Center, Gumi | Intern — integrated training environment for heterogeneous industrial and collaborative robots |
| 2021.03 – 2022.01 | Robot Dynamics and Intelligent Control Lab, Keimyung University | Undergraduate researcher — system modeling and stability design of piping robots, MFC-based actuator control |
| 2017.03 – 2023.02 | Keimyung University, Daegu | B.S. in Robotics Engineering (GPA 4.2/4.5, major 4.4/4.5) |
Ongoing Projects
Cooperative Multi-Robot Navigation in Large-Scale Indoor Workspaces
2023.05 – present
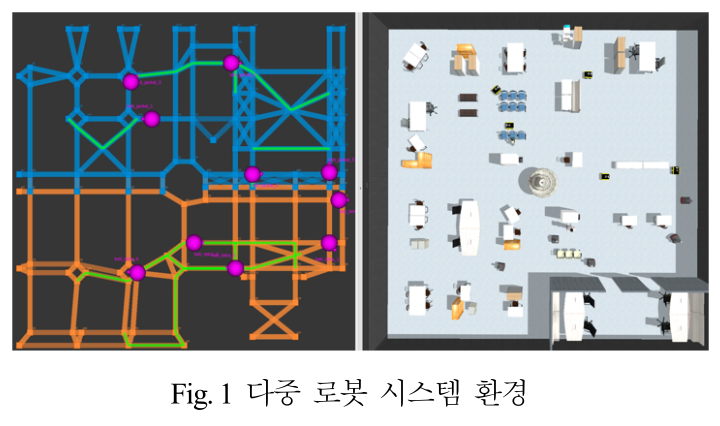
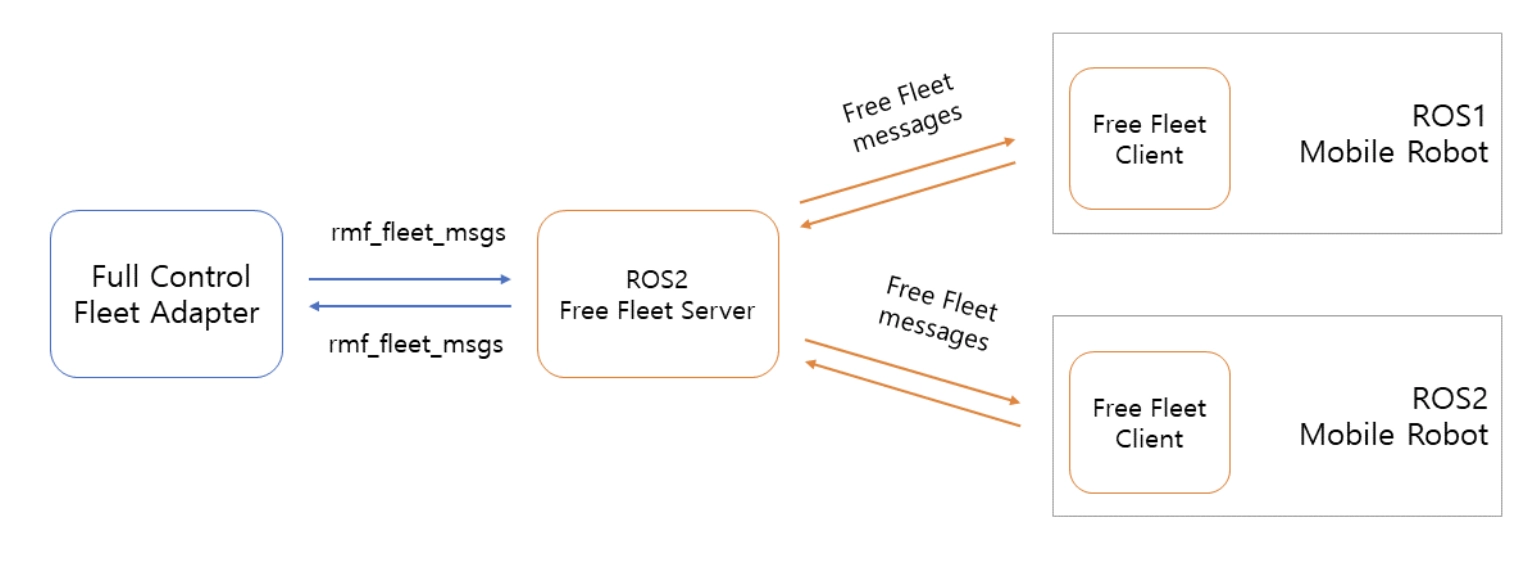
- Open-RMF fleet management and task system; 30-robot simulation to 4 real robots
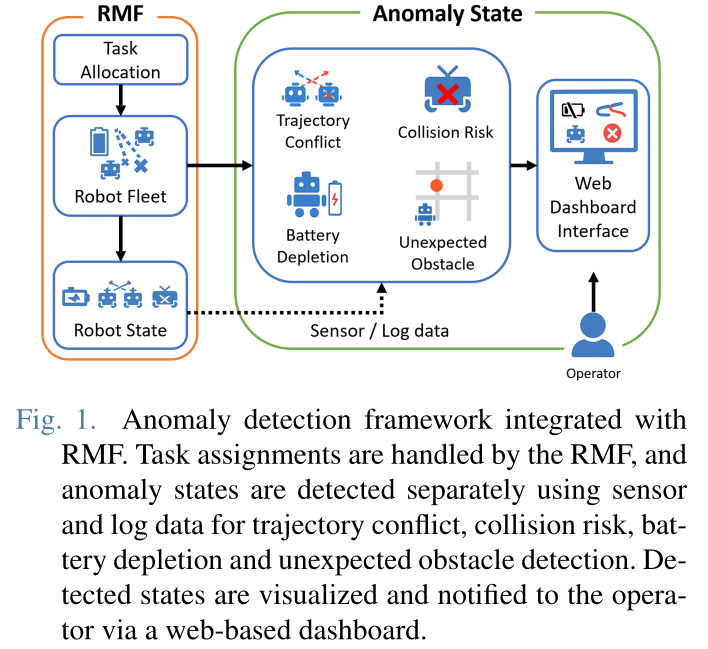
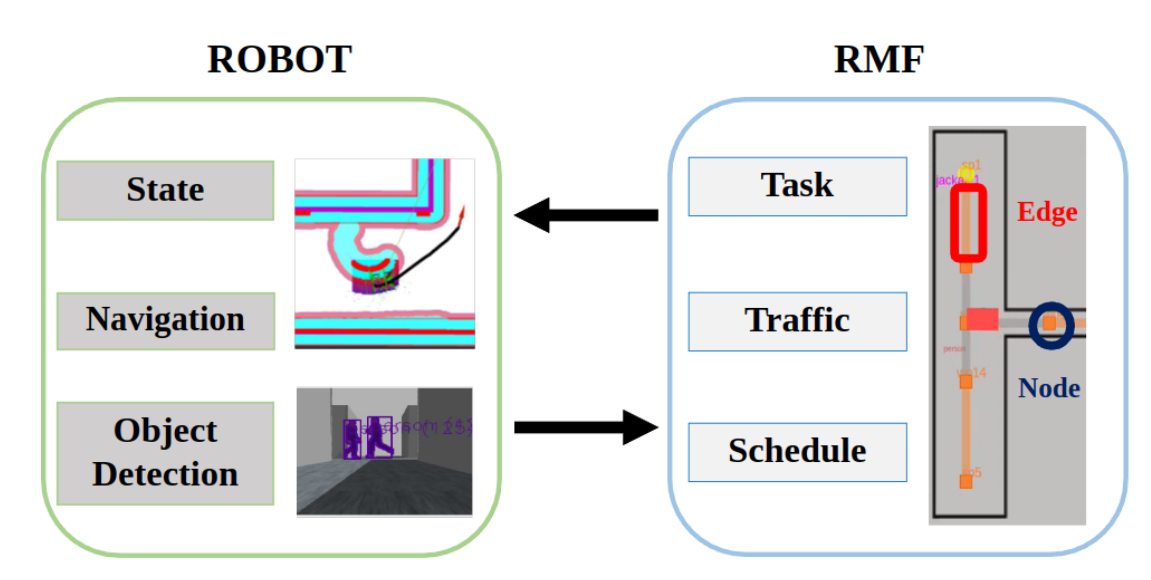
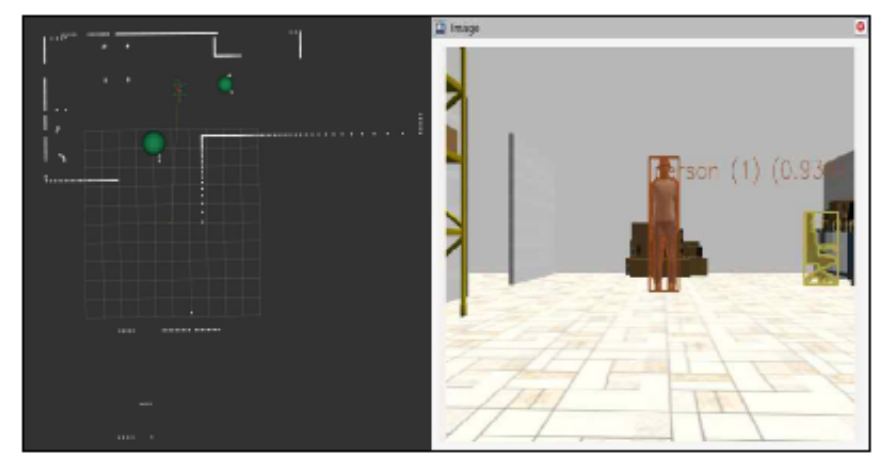
- Cooperative obstacle sharing and lane closure; fault injection and learning-based anomaly detection
- Outdoor extension: traversability navigation pipeline
Software-Defined Robot (SDR) Domain Services
2025.01 – present
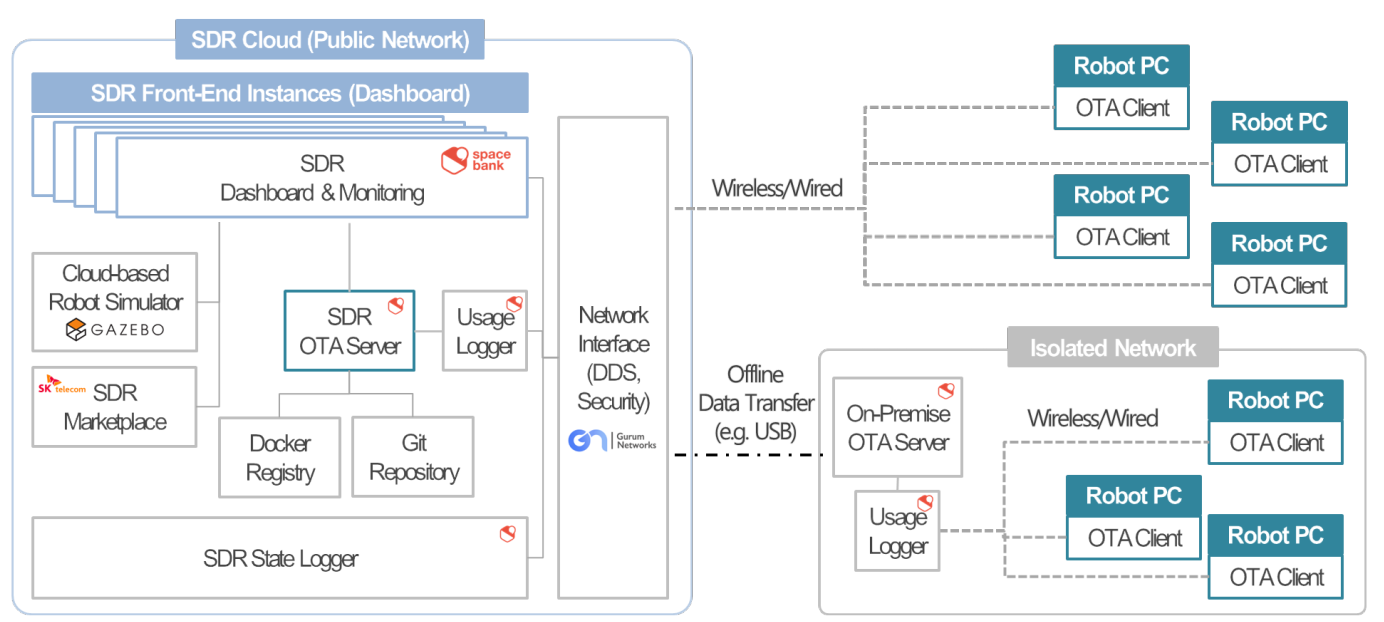
- Docker/Git OTA framework with robot profiles
- Robot–elevator multi-floor navigation and LiDAR-marker ICP docking on a real robot
- Go2 multi-floor simulation testbed and VLM mission agent
Full project write-ups are on the projects page; the CV page has the complete record.
selected publications
- A Learning-based Anomaly Detection Framework for Multi-Robot SystemsIn Conference of the Institute of Control, Robotics and Systems (ICROS 2026), Jul 2026
- Anomaly Detection and Visualization Framework for Multi-Robot Systems Using RMFIn 2025 25th International Conference on Control, Automation and Systems (ICCAS), Nov 2025
- Traversability Assessment and Path Planning Using Obstacle Recognition Information for Multi-Robot SystemIn 2024 24th International Conference on Control, Automation and Systems (ICCAS), Oct 2024
- Method for Cross-Utilization of Obstacle Recognition Information in a Multi-Robot System for Collaborative Path PlanningIn Conference of the Institute of Control, Robotics and Systems (ICROS 2024), Jul 2024
- Cooperative Autonomous Driving System for Multi-Mobile Robots Using Open-RMFIn 19th Korea Robotics Society Annual Conference (KROC 2024), Feb 2024