publications
Conference papers and a patent in reverse chronological order. First-author papers carry a 1st-author badge.
2026
- A Learning-based Anomaly Detection Framework for Multi-Robot SystemsIn Conference of the Institute of Control, Robotics and Systems (ICROS 2026), Jul 2026
2025
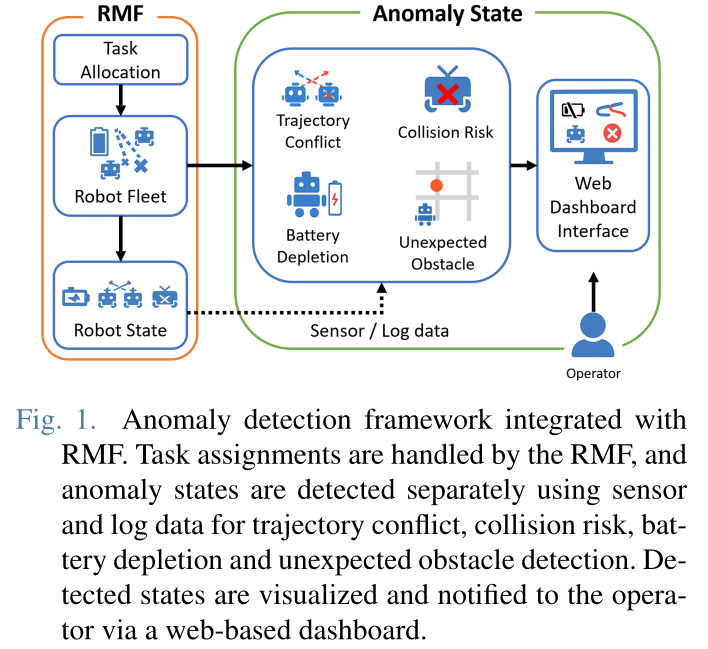
- Anomaly Detection and Visualization Framework for Multi-Robot Systems Using RMFIn 2025 25th International Conference on Control, Automation and Systems (ICCAS), Nov 2025
2024
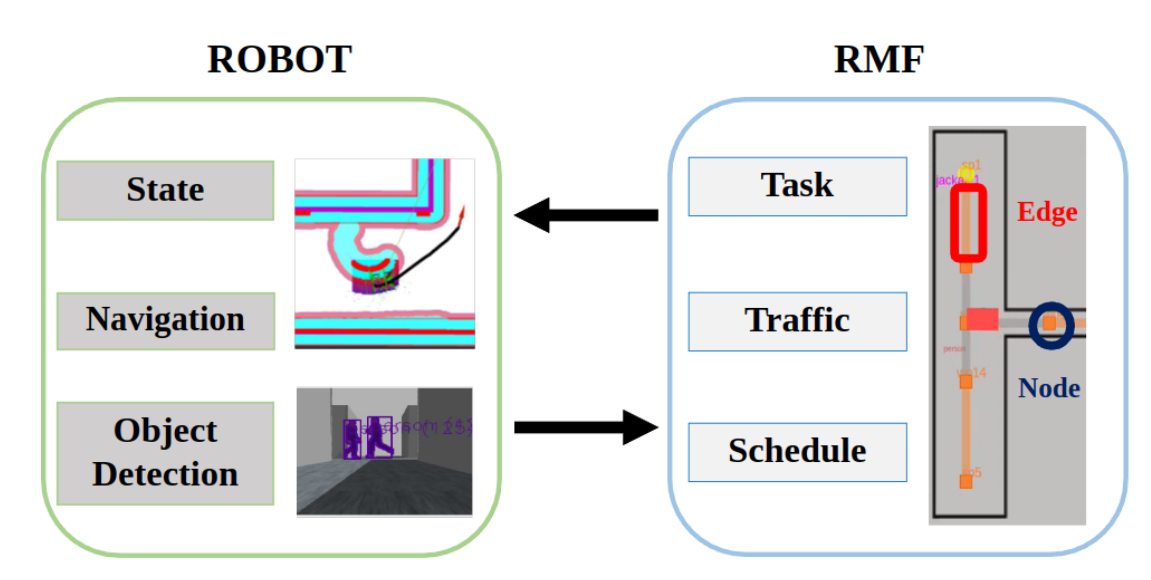
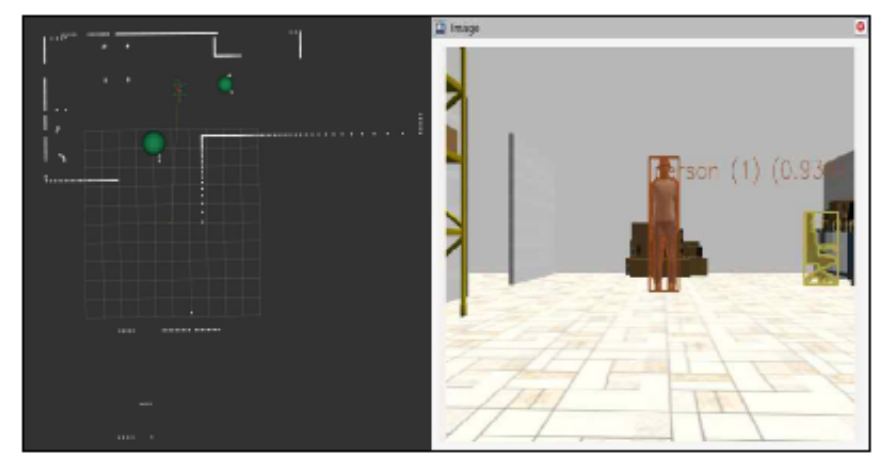
- Traversability Assessment and Path Planning Using Obstacle Recognition Information for Multi-Robot SystemIn 2024 24th International Conference on Control, Automation and Systems (ICCAS), Oct 2024
- Method for Cross-Utilization of Obstacle Recognition Information in a Multi-Robot System for Collaborative Path PlanningIn Conference of the Institute of Control, Robotics and Systems (ICROS 2024), Jul 2024
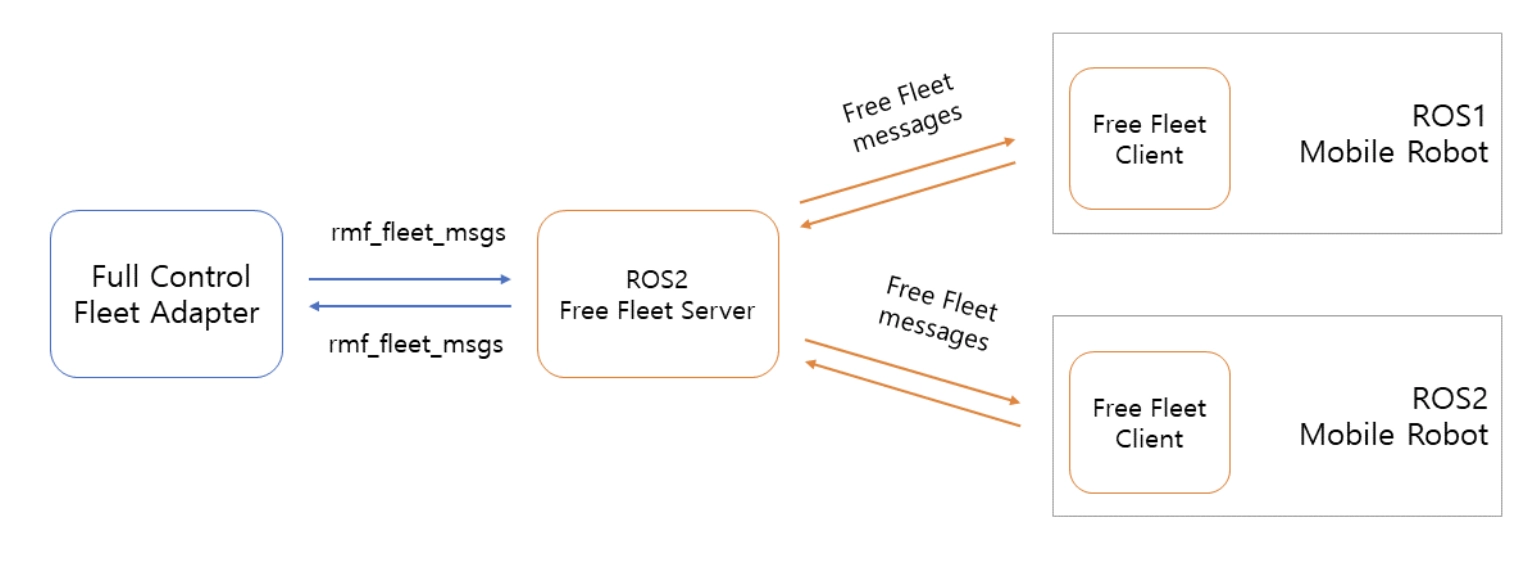
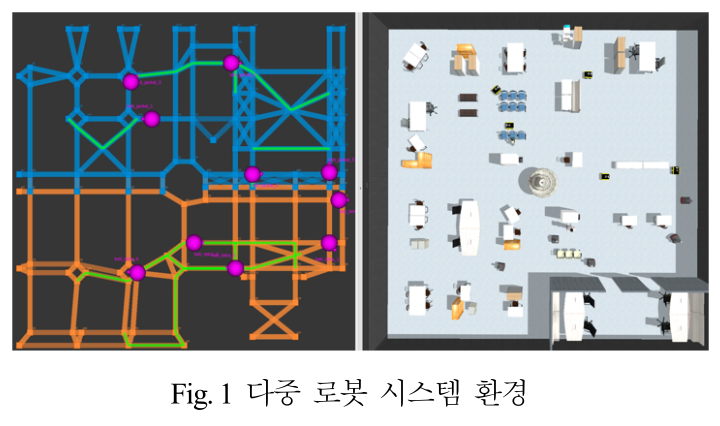
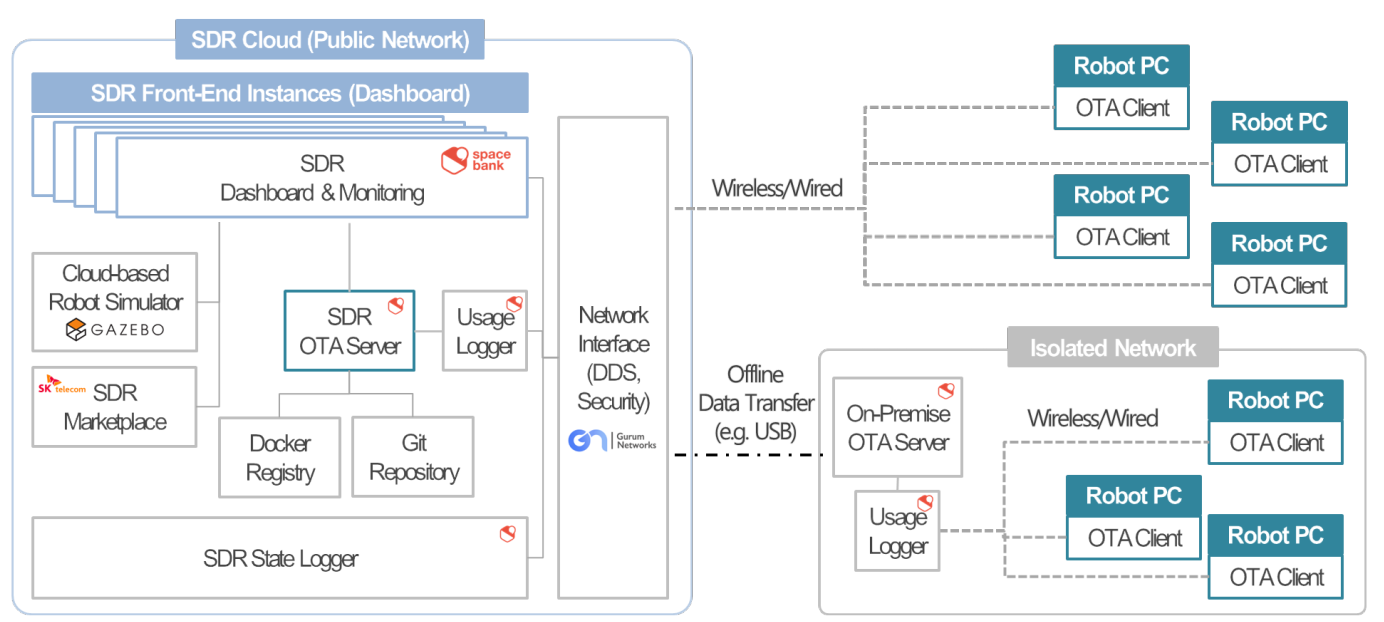
- Cooperative Autonomous Driving System for Multi-Mobile Robots Using Open-RMFIn 19th Korea Robotics Society Annual Conference (KROC 2024), Feb 2024