Heterogeneous Logistics Fleet Integration
TETRA carts, stacker AMRs and MiR under Open-RMF: free_fleet changes, docking hand-over, perception and a PySide6 GUI.
Period 2023.05 – 2025.05 · Affiliation Korea Electronics Technology Institute (KETI), Cooperative-Intelligence Robot Plus Competitiveness Support Program · Role Multi-robot operating system setup, free_fleet modification and coordinate registration, docking control handover, sensor-based obstacle perception, external system communication integration, simulation and GUI tool development
Progress by Phase
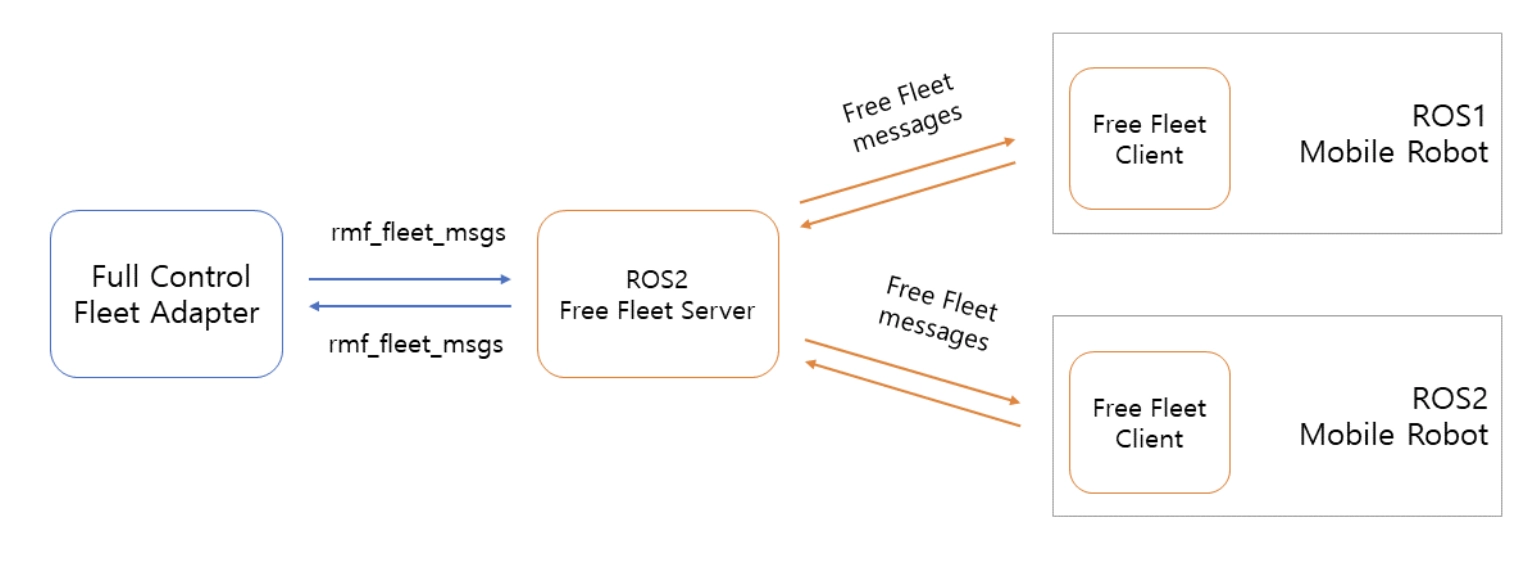
- Open-RMF and free_fleet core (2023): Built nav_graphs with traffic_editor, added a custom robot model plugin (slotcar), wrote a verification checklist for multi-robot traffic, tasks, and visualization, analyzed free_fleet and registered the traffic_editor and Nav2 map coordinate frames, integrated the real TETRA_DSV_M robot (Cartographer mapping + ros1_bridge + free_fleet), and modified the free_fleet ROS 1 ClientNode with pause and arrival topics.
- Docking, obstacle avoidance, and control handover (H2 2023): TETRA cart docking scenario, integration of rmf_obstacle_detectors and lane_blocker, design of a state machine (Moro_controller) that hands Open-RMF control over during docking and returns it afterward, and ROS 2 joy teleop.
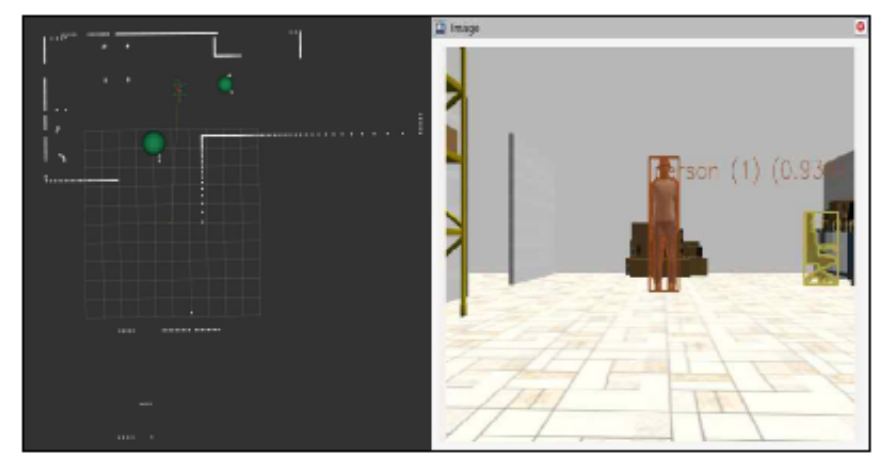
- Mapping, sensor perception, and real-robot validation (2024): Namespace-based Cartographer, PCD to PGM conversion (3D to 2D maps), LiDAR dynamic obstacle detection, camera-based YOLO object detection with 3D coordinate transformation, and a real-robot demonstration of YOLOv8 obstacle recognition with a RealSense D435.
- External system communication (H2 2024): Stacker AMR operation (MCP, VehiclePlanner, ACS, QR-based precision docking), the stacker-to-ACS TCP/IP communication protocol, and MiR 600 usage and programming.
- Simulation, networking, and GUI upgrades (2024–2025): Battery system and LiDAR obstacle-avoidance simulation, review of Isaac Sim examples and their integration with Open-RMF, MQTT networking fundamentals (Mosquitto), migration from Gazebo Classic to Gazebo Sim, RViz2 URDF and TF visualization, and an integrated GUI built with Qt Designer, PySide6, and rclpy.
Results
- Open-RMF integration of the real TETRA_DSV_M robot and a real-robot demonstration of YOLOv8 obstacle recognition.
- The project’s themes of Open-RMF cooperative autonomous driving and cross-utilization of obstacle information led to the KROC 2024 (Kim et al., 2024) and ICROS 2024 (Kim et al., 2024) papers, and the PySide6 fleet management GUI later became the foundation of the anomaly detection fault injection GUI.
Tech Stack
Open-RMF · free_fleet · Nav2 · ROS 2 / ROS 1 (ros1_bridge) · Cartographer · Gazebo (Classic / Sim) · Isaac Sim · YOLOv8 · RealSense D435/D455 · TETRA cart · Stacker AMR · MiR 600 · PySide6 / Qt · MQTT
References
2024
- Cooperative Autonomous Driving System for Multi-Mobile Robots Using Open-RMFIn 19th Korea Robotics Society Annual Conference (KROC 2024), Feb 2024
- Method for Cross-Utilization of Obstacle Recognition Information in a Multi-Robot System for Collaborative Path PlanningIn Conference of the Institute of Control, Robotics and Systems (ICROS 2024), Jul 2024